★ STARFRUUT
About Me
Michael Chen
↗ View Bio

Michael
Chen

Mechanical Engineering
Northwestern Univ.

I love expressing my creativity through building things with my hands and my mind. I'm currently looking for engineering internship opportunities — feel free to reach out.

The QuickLift2025 · Client project
UNIT.01 — The QuickLift
⤢ Open

The QuickLift

Designed a removable seat-height adjustment device for manual wheelchair users on a client project for Devices 4 the Disabled, giving six inches of lift at roughly $100 against $2,000+ powered alternatives.

Selected the mechanism by building physical mockups of three concepts — electric linear actuator, hydraulic press, and manual scissor jack — and scoring them in a weighted decision matrix against nine client-prioritized attributes. Integrated a scissor jack between custom-cut steel plates with aluminum guardrails and an extended PVC hand crank. User testing at the client site drove the final recommendations.

SolidWorks Decision Matrix User Testing Fabrication Team of 4
quicklift.jpg
⤢ Open
QuickLift scissor jack lift device
Expressive Helmet2024–26 · Solo build
UNIT.02 — Expressive Helmet System
⤢ Open

Expressive Helmet System

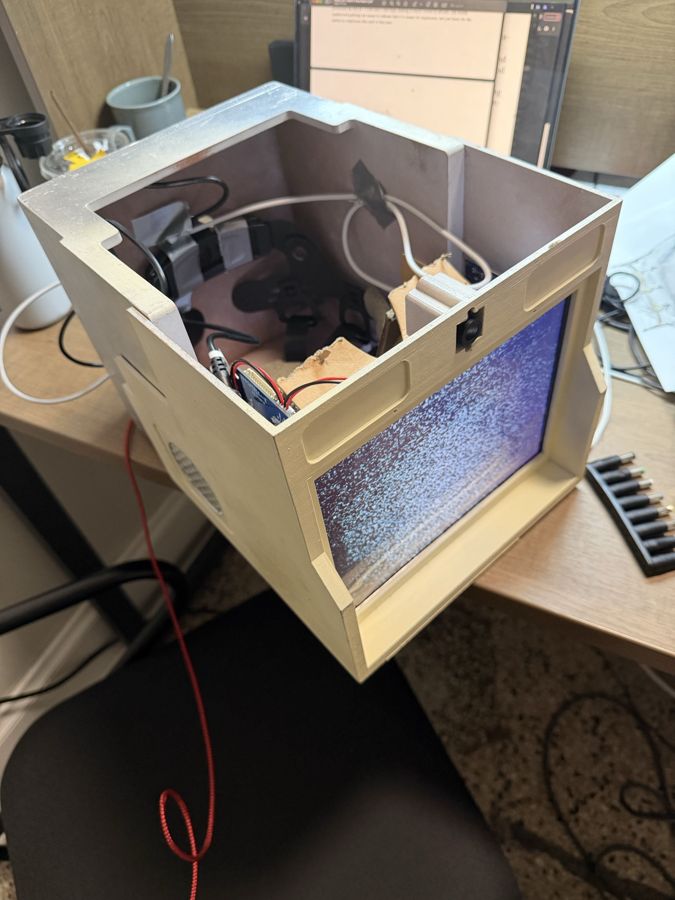
A wearable helmet with an outward-facing display, built for performing music. Mark 1 was a fully self-designed 3D-printed structure with a 64x64 LED array driven live by accelerometer data, using a periscope for forward vision — after a month of work it was heavy, bulky, and hard to see out of.

Mark 2 replaced the periscope with an analog camera-to-display system: cameras feeding a 1080p internal screen driven over DVI from an Adafruit Feather RP2040. Lighter, with substantially better visibility. Mark 3 is in planning — stereoscopic cameras, mouth tracking for facial detection, and a lighter enclosure.

C++ Python Sensors & Displays 3D Printing 2 Builds Solo Project
helmet.jpg
⤢ Open
Custom-printed housing with the outward-facing display powered on
Automated Robotic Guitar2025– · NURC team
UNIT.03 — Automated Robotic Guitar
⤢ Open

Automated Robotic Guitar

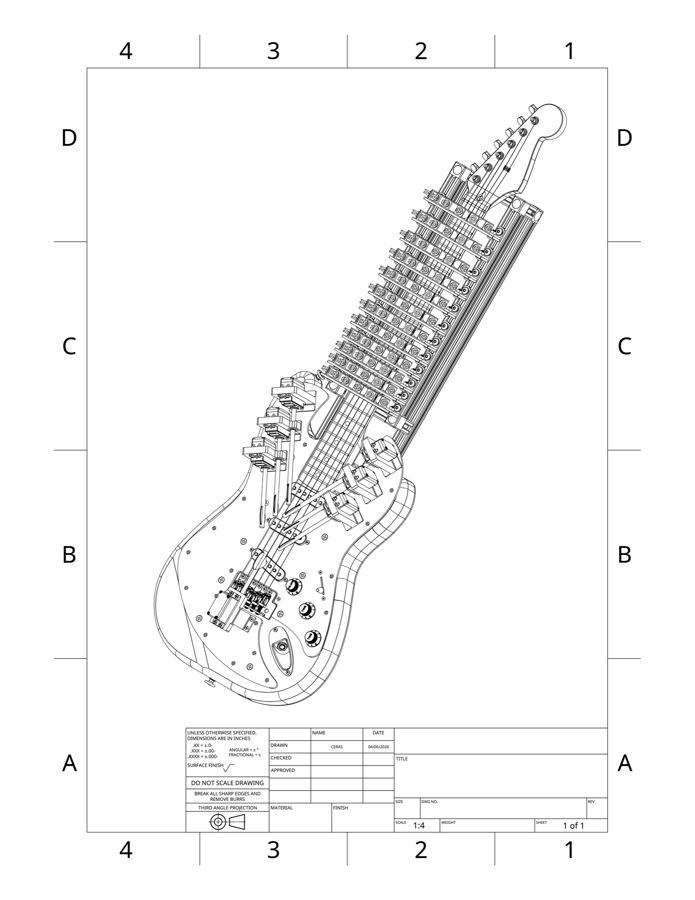
Lead the plucking and strumming subsystems on an automated robotic guitar — two of four subsystems, integrating with a teammate's solenoid fretting system.

Engineered a servo-driven rotational plucking mechanism on ball bearings with custom PLA mounts, and a servo strummer that sweeps a pick in an arc across the strings. The instrument is not yet functional; currently building a linear-solenoid selective string-muting mechanism to control sustain and expand the instrument to three articulations.

Onshape 3D Printing Mechatronics In Progress Club Team
robotic_guitar.jpg
⤢ Open
CAD drawing of the robotic guitar body and headstock
3-Axis Soft Metrology Rig2026– · HAND ERC research
UNIT.04 — 3-Axis Soft Metrology Rig
⤢ Open

3-Axis Soft Metrology Rig

Building a calibration rig to characterize soft tactile sensors, translating a 0.1 kPa sensitivity target into hardware specifications and delivering on a 12-week schedule and a $3,000 budget.

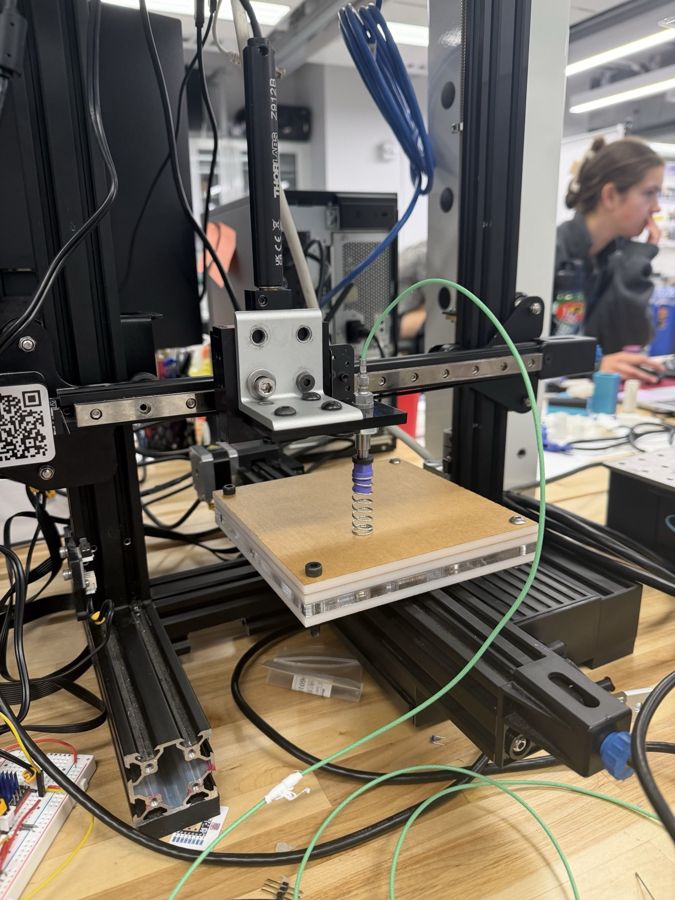
Benchmarked eight actuator technologies — ball screws, voice coils, and three classes of piezoelectric stage — against force resolution, cost, and lead time, then adapted an existing 3-axis gantry rather than buying new motion hardware. Drives Thorlabs servo-actuators from a Teensy 4.1 over low-level hex commands, with a Series Elastic Actuator isolating the sensing path from mechanical noise and stiction, plus a modular swappable test bed for changing specimen fixtures without rebuilding the rig.

Metrology Teensy 4.1 Data Acquisition Vendor Sourcing In Progress Solo Research
metrology_rig.jpg
⤢ Open
3-Axis Soft Metrology Rig working prototype in the lab
// PROJECT.DATA
New Message